AI-powered processing
Embedded NVIDIA GPU and CPU for real-time analysis.
X2000 Vehicle Computer
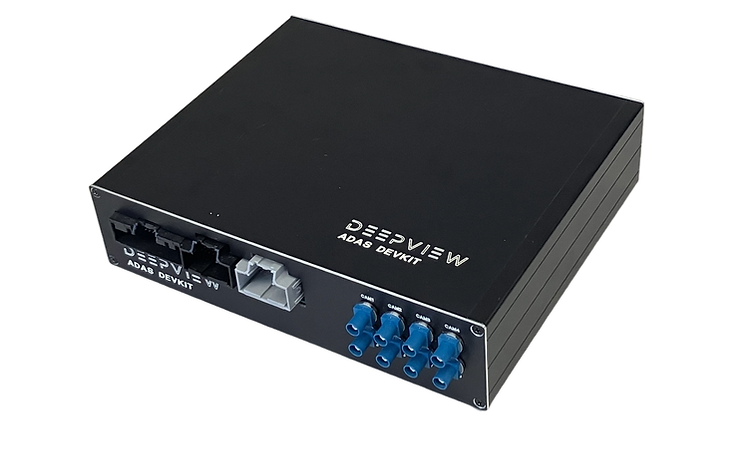
The X2000 is an AI vehicle computer and drive-by-wire development kit. It gives ground vehicle engineering teams perception, vehicle control and data logging on one rugged, fanless unit, with 100% of the source code available for your use.
Capabilities
Embedded NVIDIA GPU and CPU for real-time analysis.
All vision processing takes place on the vehicle computer. No link to a data center is needed to drive.
Fanless, rugged construction for industrial environments.
Steering, throttle and brake commands at 100 Hz over CAN-FD.
AR0234 camera over GMSL2, with built-in support for up to eight cameras.
Stores 1 TB on board and streams video and CAN data to your backend.
Software reference designs
Every module ships with source. Your team can read it, change it and build on it.
Perception and control
The X2000 reads the cameras, runs the neural network and commands the vehicle from one computer. Lane centering runs in the vehicle in real time using an adapted OpenPilot model.
Drive-by-wire has been integrated on Ford vehicles. Other vehicle platforms are supported on request, which is where a ground vehicle program would start.
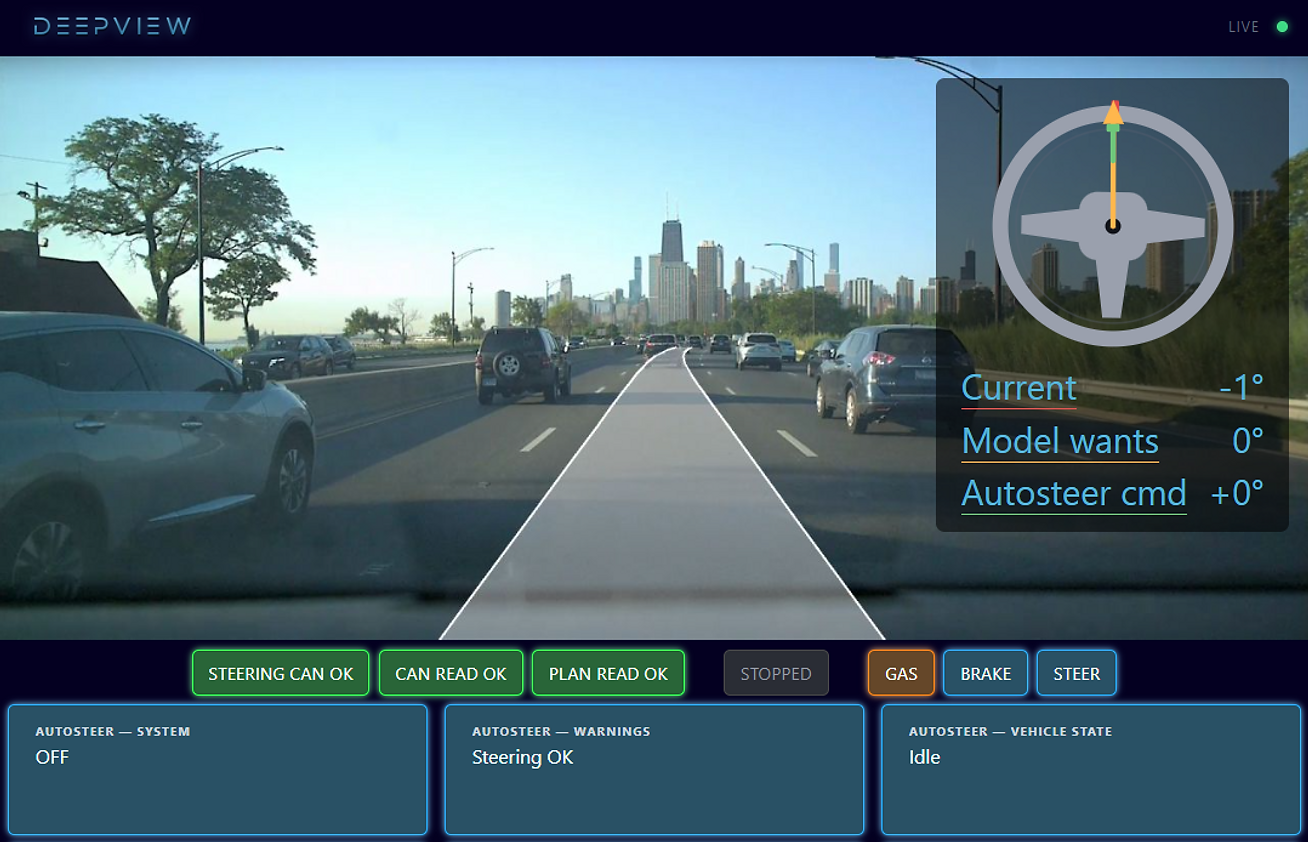
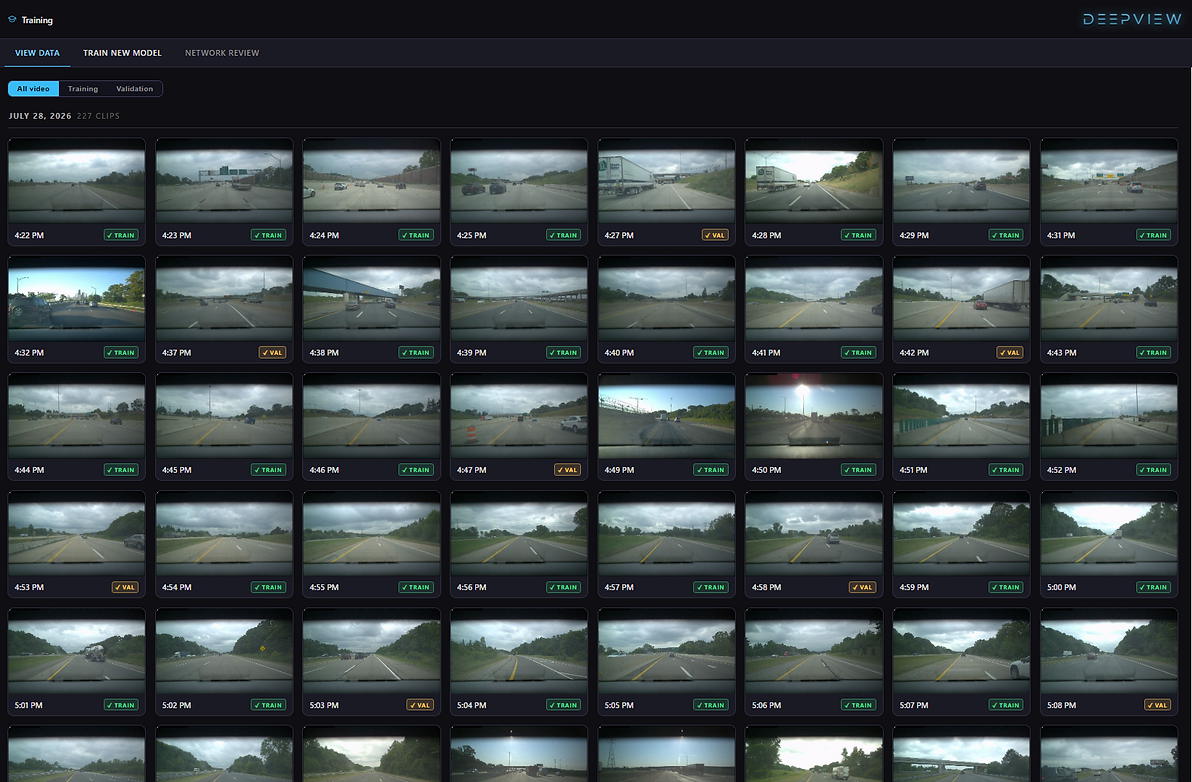
Recorded drives upload from X2000-equipped vehicles to your data center. Models retrain on your fleet's own driving data, and improved models go back to the vehicles.
Program path
One X2000 kit is fitted to a test vehicle. Cameras, compute and vehicle control run together.
Drive-by-wire and sensors are adapted to your vehicle platform and its CAN network.
Your engineers build the autonomy functions the program needs, starting from the source code.
More vehicles are equipped. Every drive is logged, and models retrain on the fleet data.
The proven design moves to production hardware and software, with Deepview engineering support through the transition.
Engineering support
We adapt drive-by-wire and sensors to your vehicle platform.
Deepview engineers work inside your program on AI software, training and inference.
Designed and built in Rochester, Michigan.
The X2000 is a development kit for engineering and test use. Specifications are from the X2000 datasheet.
Tell us about the vehicle and the program. Write to sales@deepviewai.com or book a call.